Some applications require the use of automation components with a control interface other than the EtherCAT bus.
For this purpose, ISAC offers gateway modules for connection to other buses or for implementing physical interfaces.
These modules offer the Yaskawa Mechatrolink bus interface, CANopen. They also implement the control and measurement system for servo drives with speed setting proportional to the analog input signal and feedback via a TTL encoder or SSI interface.
Finally, they implement the control and measurement system for servo drives with position setting via pulse and direction signal generation at the input and feedback with TTL encoder or SSI interface.
The modules implement the physical interface and contain the minimum possible on-board intelligence to maximize efficiency and upgradability. The software running in the central unit implements all communication protocols to synchronize actions between the buses and centralize configuration parameters.
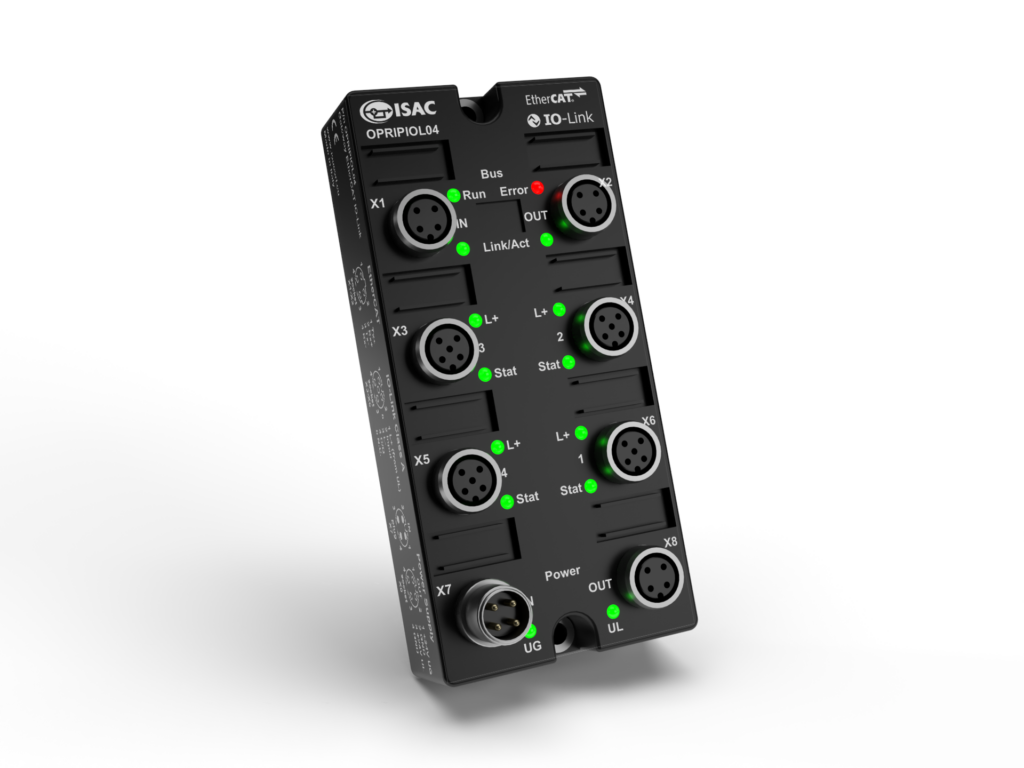
OPRIPIOL04
IP67 gateway between EtherCAT network and IO-Link devices.